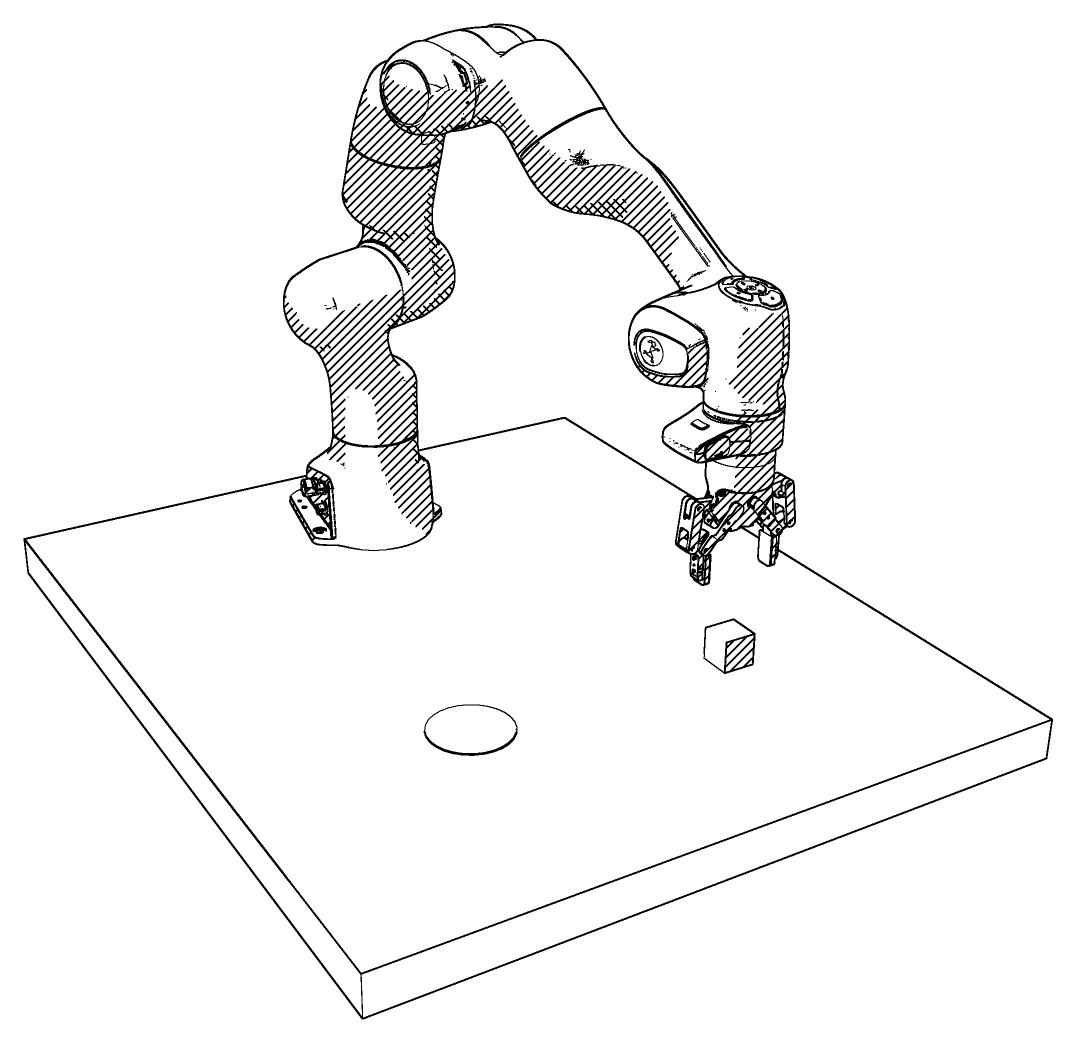
Fig. 1. A Franka Panda arm in our simulator, about to pick up a block. Rendered straight from the sim. We vary the block, the camera and the lights, and watch where the policy fails.
Pre-deployment testing for robot policies. You send us your policy and a description of the scene. Our agents build the simulations, run thousands of varied episodes, and send you back a failure report: where it breaks, how, and why.
Become a design partner → kristian@diffusr.ai
Fig. 1. A Franka Panda arm in our simulator, about to pick up a block. Rendered straight from the sim. We vary the block, the camera and the lights, and watch where the policy fails.
A real example from our own test bench: an ACT policy on a simulated Franka Panda arm, picking up a block and placing it on a target. 50 unseen episodes per scenario.
| scenario | success | main failure |
|---|---|---|
| same as training | 39/50 (78%) | missed grasp ×7 |
| block outside the trained area | 4/50 (8%) | missed grasp ×45 |
| camera moved a few cm | 15/50 (30%) | missed grasp ×26 |
| dimmer lighting | 31/50 (62%) | missed grasp ×17 |
What it told us: once the block is in hand, placing mostly works. The weak point is the grasp, and it collapses when the block starts somewhere the demonstrations never covered. More demonstrations from the same area did not fix it. Every row comes with failure videos, so you can see each miss.
Robotics teams training manipulation policies (imitation learning, VLAs, RL) who want to know how reliable a policy is before it goes on a real robot or to a customer.
We are working with a small number of early teams. You give us one real task; we build it in simulation, run it, and send you the report. In return we ask for honest feedback, and, where you can, a comparison with what you see on the real robot.
Your policy stays private. If you can't share weights, tell us; we can work out running it in your own cloud account.
Interested? Email kristian@diffusr.ai. A few lines about your robot and task is enough.
Built on MuJoCo and LeRobot.